 Tech Report
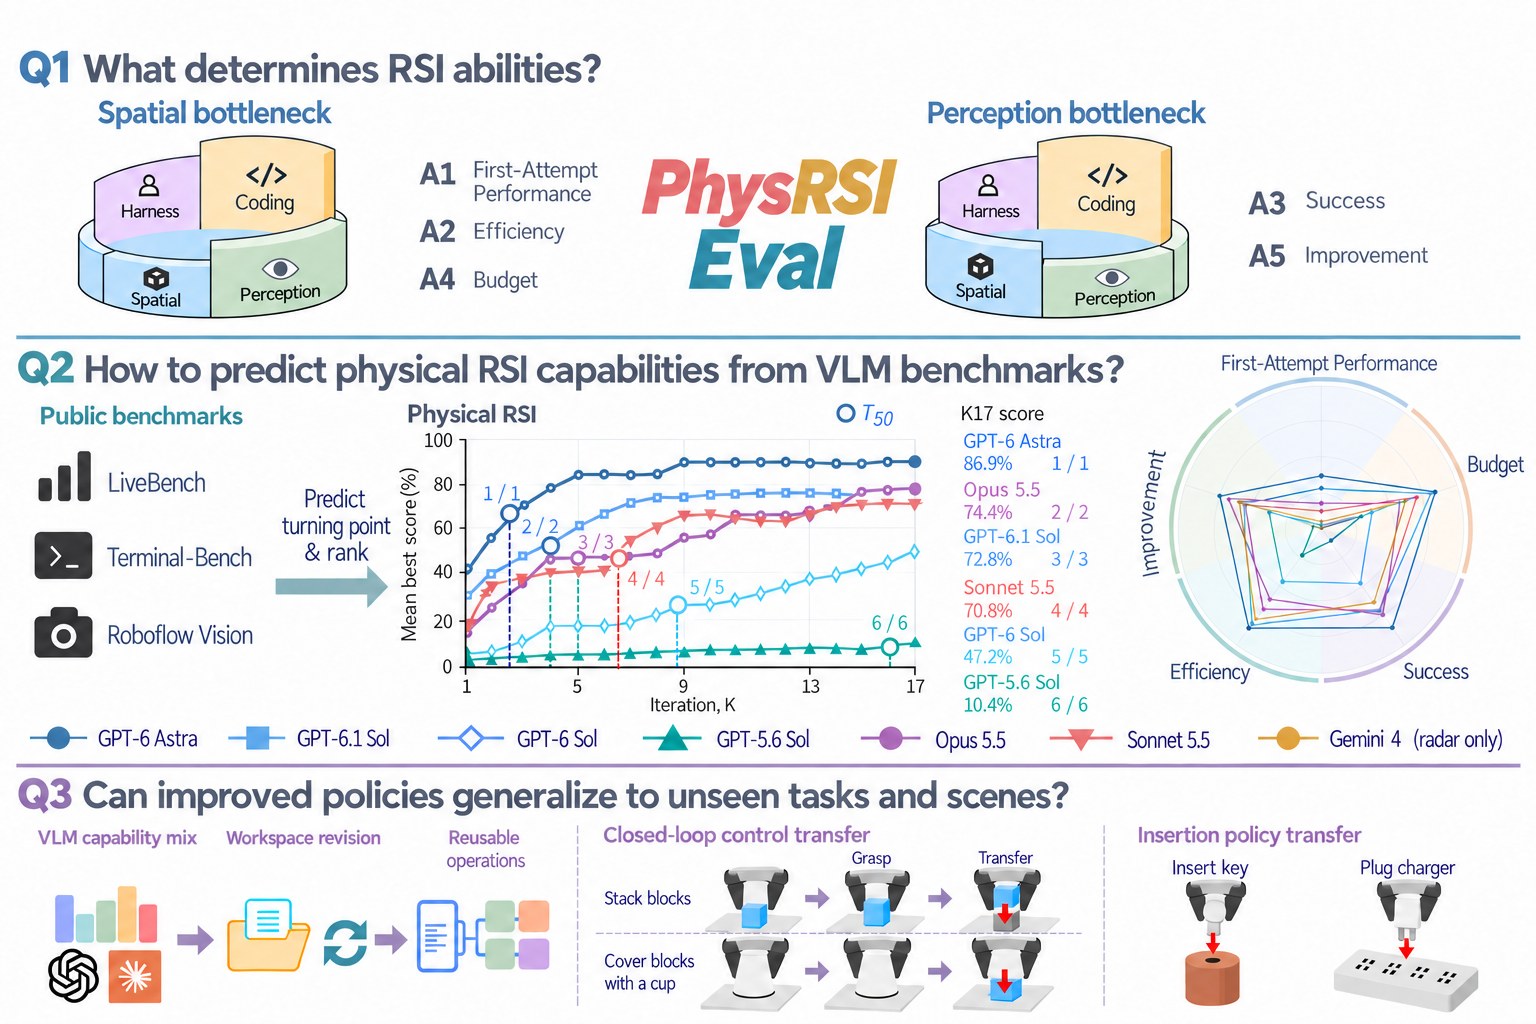
Systematically Exploring the Capabilities of GPT-6 Astra as Embodied Policies
Technical report, arXiv, 2026.
I am a senior undergraduate majoring in Software Engineering at Nankai University and an incoming PhD student at EPIC Lab, Peking University, advised by Prof. He Wang.
Currently, I work on humanoid robotics as a research intern at  GALBOT, advised by Prof. He Wang and Prof. Li Yi. Previously, I was a research intern at THUNLP, Tsinghua University, where I studied multimodal reasoning with Prof. Peng Li and Prof. Yang Liu.
At GALBOT, I explore humanoid robot learning across S2 reasoning, S1 VLA/WAM policies, and S0 whole-body control. My work includes developing humanoid VLA/WAM policies for loco-manipulation, investigating the training of AstraBrain-WBC as a whole-body control foundation model and low-level cerebellum for higher-level policies, and exploring human egocentric data for humanoid learning.
My research focuses on building generalizable embodied agents that can perceive, reason, and act in complex real-world environments.
Please feel free to contact me if you are interested in my work or would like to chat about any topic.
* Equal contribution; † Corresponding author.
Tech ReportSystematically Exploring the Capabilities of GPT-6 Astra as Embodied Policies
Technical report, arXiv, 2026.
 ECCV
HumanTracker: Towards Comprehensive and Human-Aligned Motion Tracking Benchmark
European Conference on Computer Vision (ECCV), 2026.
 CVPR
Humanoid-GPT: Scaling Data and Structure for Zero-Shot Motion Tracking
IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), 2026.
 EMNLP
Evaluating Time Awareness and Cross-modal Active Perception of Large Models via 4D Escape Room Task
Conference on Empirical Methods in Natural Language Processing (EMNLP), 2026.
 NeurIPS WS
Thinking with Visual Abstract: Enhancing Multimodal Reasoning via Visual Abstraction
NeurIPS 2025 Workshop.
 arXiv
 ICML
LIMMT: Less is More for Motion Tracking
International Conference on Machine Learning (ICML), 2026.